Wissenschaftliche Arbeiten
Unser Wissensschatz für innovative Drohnen-Technologie.
-
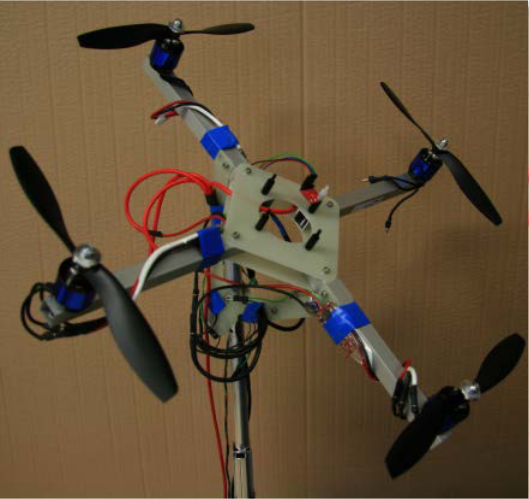
Avionic Control Systems for Education and Development
Nils Gageik, Atheel Redah und Sergio Montenegro · 01/2012 INTED Conference
This paper describes, explains and evaluates two avionic control systems for education and development, which have been implemented as educational tools for subjects in the study path Information Technology for Aerospace...
-
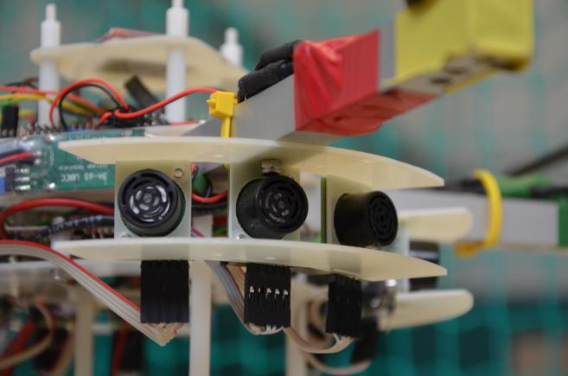
Obstacle Detection and Collision Avoidance using Ultrasonic Distance Sensors for Autonomous Quadrocopter
Nils Gageik, Thilo Müller und Sergio Montenegro · 11/2012 UAVveek Workshop
A simple approach for obstacle detection and collision avoidance of an autonomous flying quadrocopter using low-cost ultrasonic sensors and simple data fusion...
-
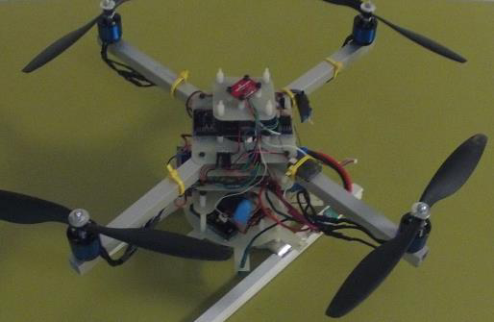
Data Fusion Principles for Height Control and Autonomous Landing of a Quadrocopter
Nils Gageik, Julian Rothe und Sergio Montenegro · 11/2012 UAVveek Workshop
A simple algorithm (weighted filter) for data fusion of multiple sensors to obtain the most reliable value...
-
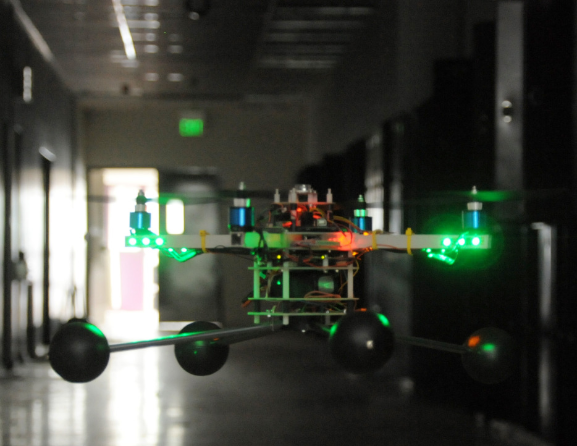
Waypoint Flight Parameter Comparison of an Autonomous UAV
Nils Gageik, Michael Strohmeier und Sergio Montenegro · 05/2013 IJAIA Vol.4 Nr.3 Journal
The present paper compares the effect of different waypoint parameters on the flight performance of a special autonomous indoor UAV (unmanned aerial vehicle) fusing ultrasonic, inertial, pressure and optical sensors for 3D positioning and controlling...
-
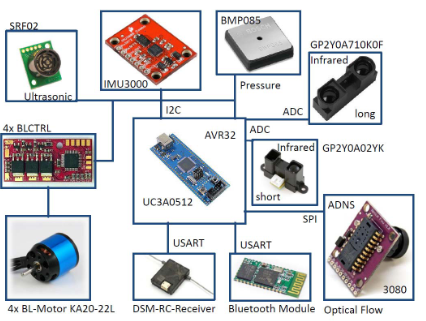
An Autonomous UAV with an Optical Flow Sensor for Positioning and Navigation
Nils Gageik, Michael Strohmeier und Sergio Montenegro · 10/2013 Intech IJARS Journal
A procedure to control all six DOF (degrees of freedom) of a UAV (unmanned aerial vehicle) without an external reference system and to enable fully autonomous flight...
-
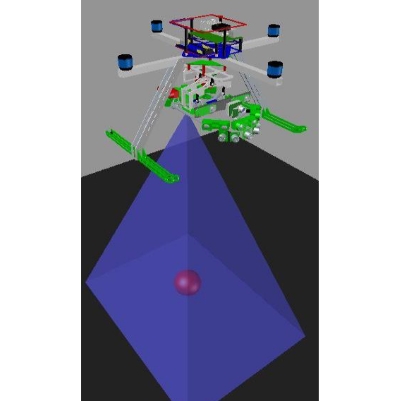
Autonomous Quadrocopter for Search, Count and Localization of Objects
Nils Gageik, Christian Reul und Sergio Montenegro · 11/2013 UAV World Conference
The present paper describes and evaluates the design and implementation of a fully autonomous quadrocopter, which is capable of self-reliant search, count and localization of a predefined object on the ground inside a room...
-
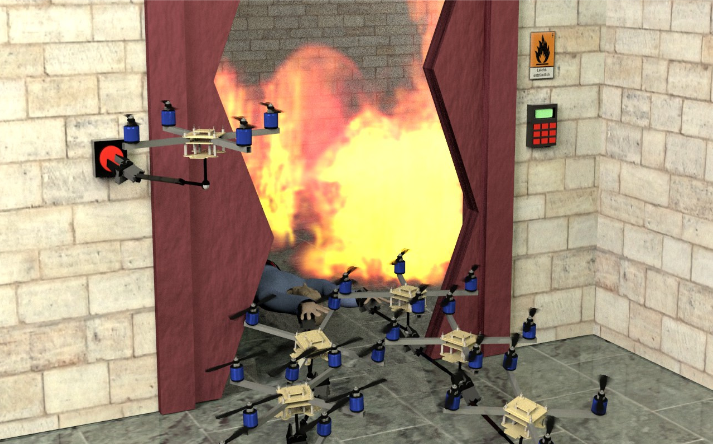
A Review on Distributed Control Of Cooperating Mini UAVs
Nils Gageik, Christian Reul und Sergio Montenegro · 05/2014 IJAIA Vol.5 Nr.4 Journal
... This paper presents an overview of the main aspects in the domain of distributed control of cooperating MUAVs to facilitate the potential users in this fascinating field. Furthermore it gives an overview on state of the art in MUAV technologies e.g. Photonic Mixer Devices (PMD) camera, distributed control methods and on-going work and challenges...
-
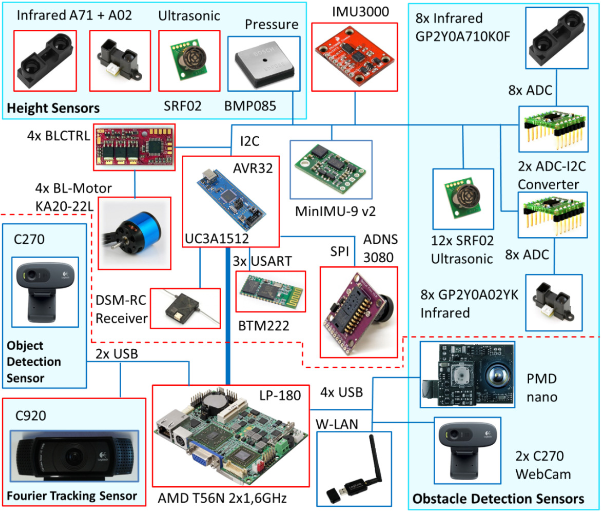
Complementary Vision Based Data Fusion for Robust Positioning and Directed Flight of an Autonomous Quadrocopter
Nils Gageik, Eric Reinthal, Paul Benz und Sergio Montenegro · 09/2014 IJAIA Vol.5 Nr.5 Journal
The present paper describes an improved 4 DOF (x/y/z/yaw) vision based positioning solution for fully 6 DOF autonomous UAVs, optimised in terms of computation and development costs as well as robustness and performance...
-
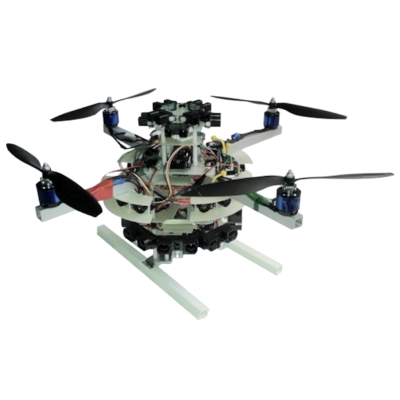
Obstacle Detection and Collision Avoidance for a UAV With Complementary Low-Cost Sensors
Nils Gageik, Paul Benz und Sergio Montenegro · 05/2015 IEEE Access Journal
This paper demonstrates an innovative and simple solution for obstacle detection and collision avoidance of unmanned aerial vehicles (UAVs) optimized for and evaluated with quadrotors...