Example implementation of the Kalman filter
Dieser Artikel ist auch auf Deutsch verfügbar
Episode 7: Kalman-Filter 2/2
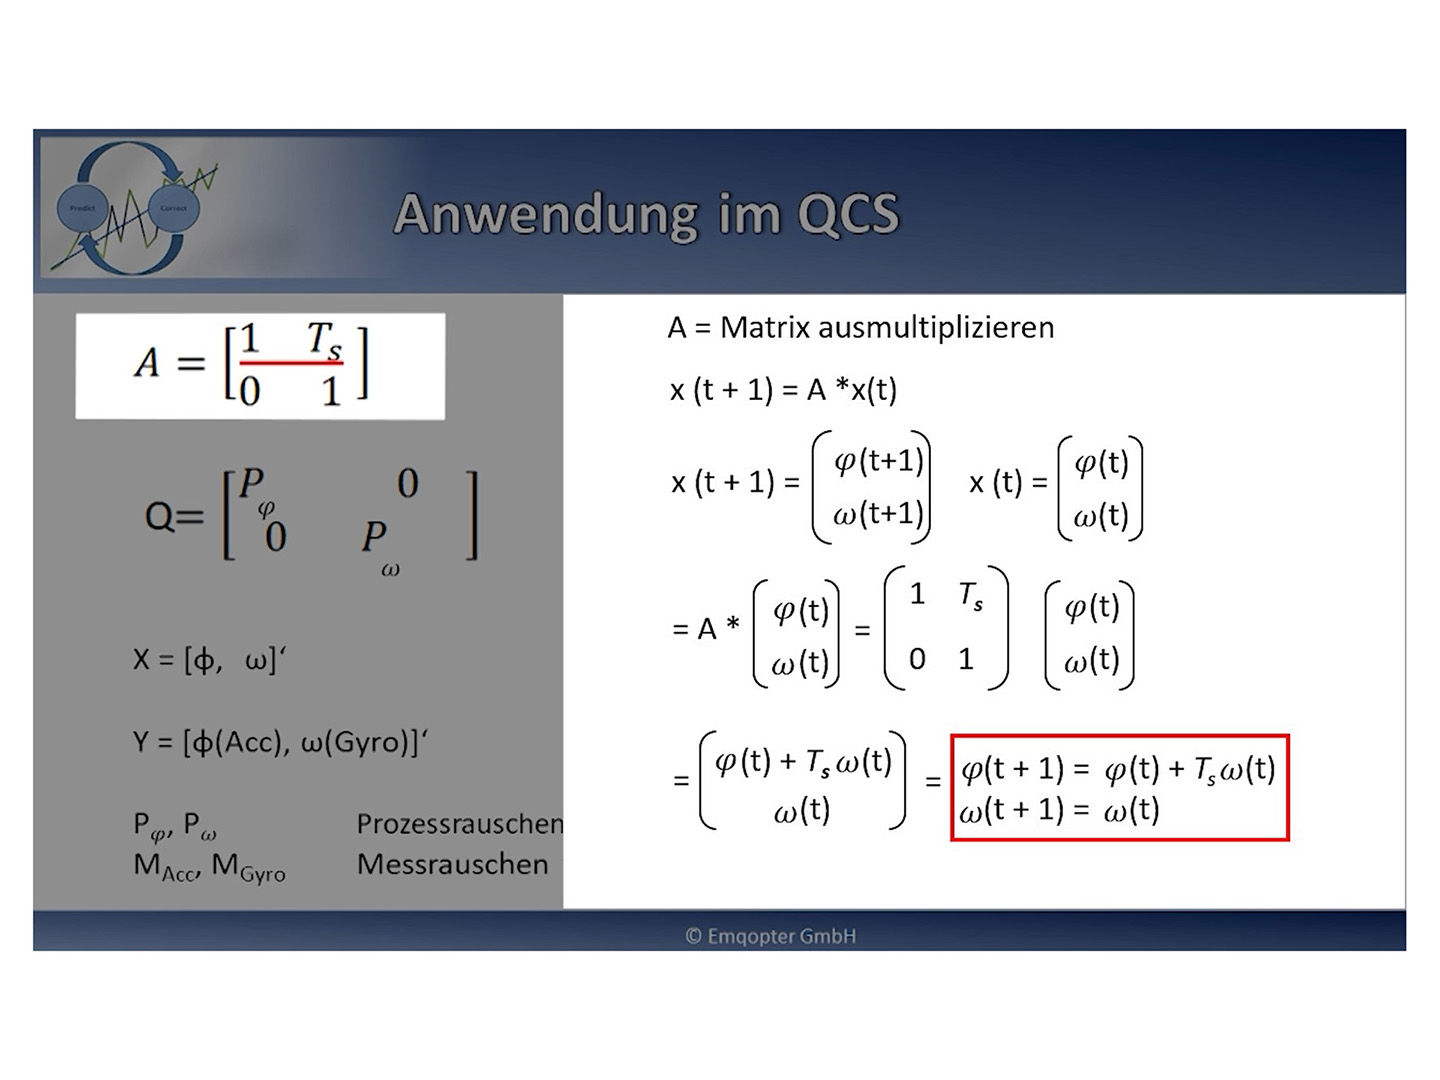
You stayed tuned to the end of the last episode of our Drone Tech Academy on the basics of the Kalman filter and are now curious about how a Kalman filter is implemented in software? Then it's time to get down to the nitty gritty. In the latest episode, Dr. Nils Gageik uses our software framework EMQ_QCSF to show how the bias drift of a gyroscope is compensated for.
Here you can directly get to our newest episode of the Drone Tech Academy!
By the way, the EMQ_QCSF framework is one of five differently extensive software frameworks that are all included in the product scope of the complete packages of our Quadrotor Control System (QCS) teaching and development platform. From beginner to professional, there is something for everyone. Detailed information can be found on the product page of our QCS. You can arrange your free, no-obligation web demo here.
You don't want to miss an episode of the Drone Tech Academy in the future?
Then subscribe to our YouTube channel. There you will also find the link as well as further videos and updates on the topic of drones and Emqopter.